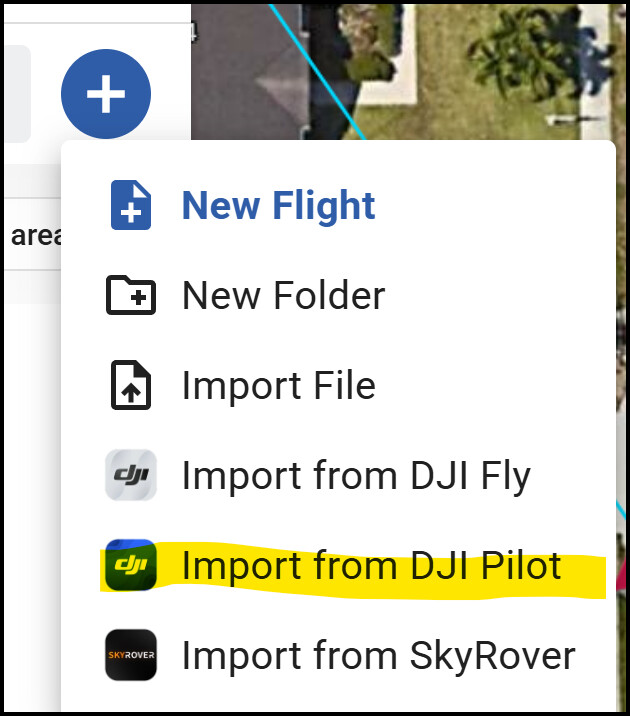
So, I created a Waypoint mission with my M3E using the DJI Pilot 2 App. The mission imported fine into Litchi Hub using the Litch Bridge Service. However, the Gimbal Settings on each Waypoint defaulted to zero degrees (horizontal). The Bridge or the Hub ignored the Gimbal setting of the recorded mission from DJI Pilot 2. Is the “Import from DJI Pilot” compatible with DJI Pilot 2, or is this a bug? (As an aside, There is no Gimbal issue importing from a DJI FLY waypoint mission, just a DJI Pilot 2 Waypoint mission).
That was a bug which should now be fixed. Thanks for reporting it!
1 Like
Thanks, I’ll test it out!
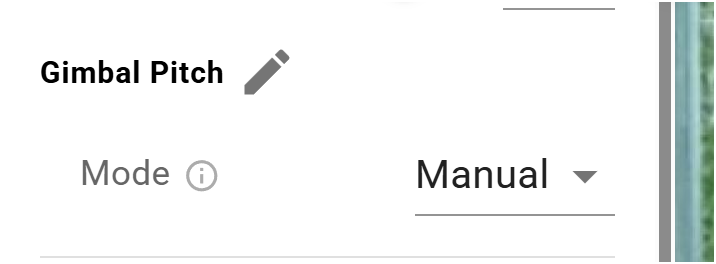
Unfortunately, Testing showed no change. The Gimbal setting is fixed at 0 degrees and when imported to Litchi Hub, the Gimbal shows “Manual”. Changing this does not help. Gimbal still locked at 0 degrees. Nothing came over fro DJI Pilot 2 Waypoint Gimbal settings.
Works fine on my end when planning for M3E in DJI Pilot 2 then using Import from DJI Pilot.
Make sure to reload/refresh the Hub in your browser so you’re on latest version then try again, it should work. If the problem persists, post your KMZ file
Hello, I restarted everything and tried the Litchi Bridge again, but had the dame issue. Should I uninstall and reinstall the Litchi Bridge? Attached is the DJI KMZ file off of the Enterprise Pro controller. Thanks.
Waypoint2.kmz (2.5 KB)
This KMZ is in manual gimbal mode, so the Hub imports it correctly.
<wpml:gimbalPitchMode>manual</wpml:gimbalPitchMode>
OK, but the gimbal pitch I recorded on the DJI Waypoints is not coming through to Litchi Hub. They are all forced to Zero. DJI Fly Waypoints come across with correct Gimbal settings but DJI Pilot 2 created Waypoints are coming across with 0 degrees on them. I’ve created on the Fly waypoints with the M3E both using the Waypoint Create button on the Controller, and using the Create Photo button. Neither method keeps the Gimbal angles on the waypoints in Litchi. Any ideas if I should reinstall the hub? If you have a successful method let me know. Thanks, Daniel.
The test I did is to plan a waypoint flight inside DJI Pilot 2 (drone not connected), set ‘Gimbal Control’ to ‘For Each Waypoint’, each waypoint with its own custom gimbal pitch angle. Then I used Litchi Hub’s ‘Import from DJI Pilot’, and the newly imported flight in Litchi Hub shows Gimbal Mode set to Transition and all the correct angles.
The KMZ you sent does not have any gimbal angle, so perhaps you are importing the wrong flight, or maybe your gimbal angles were overwritten by something else.
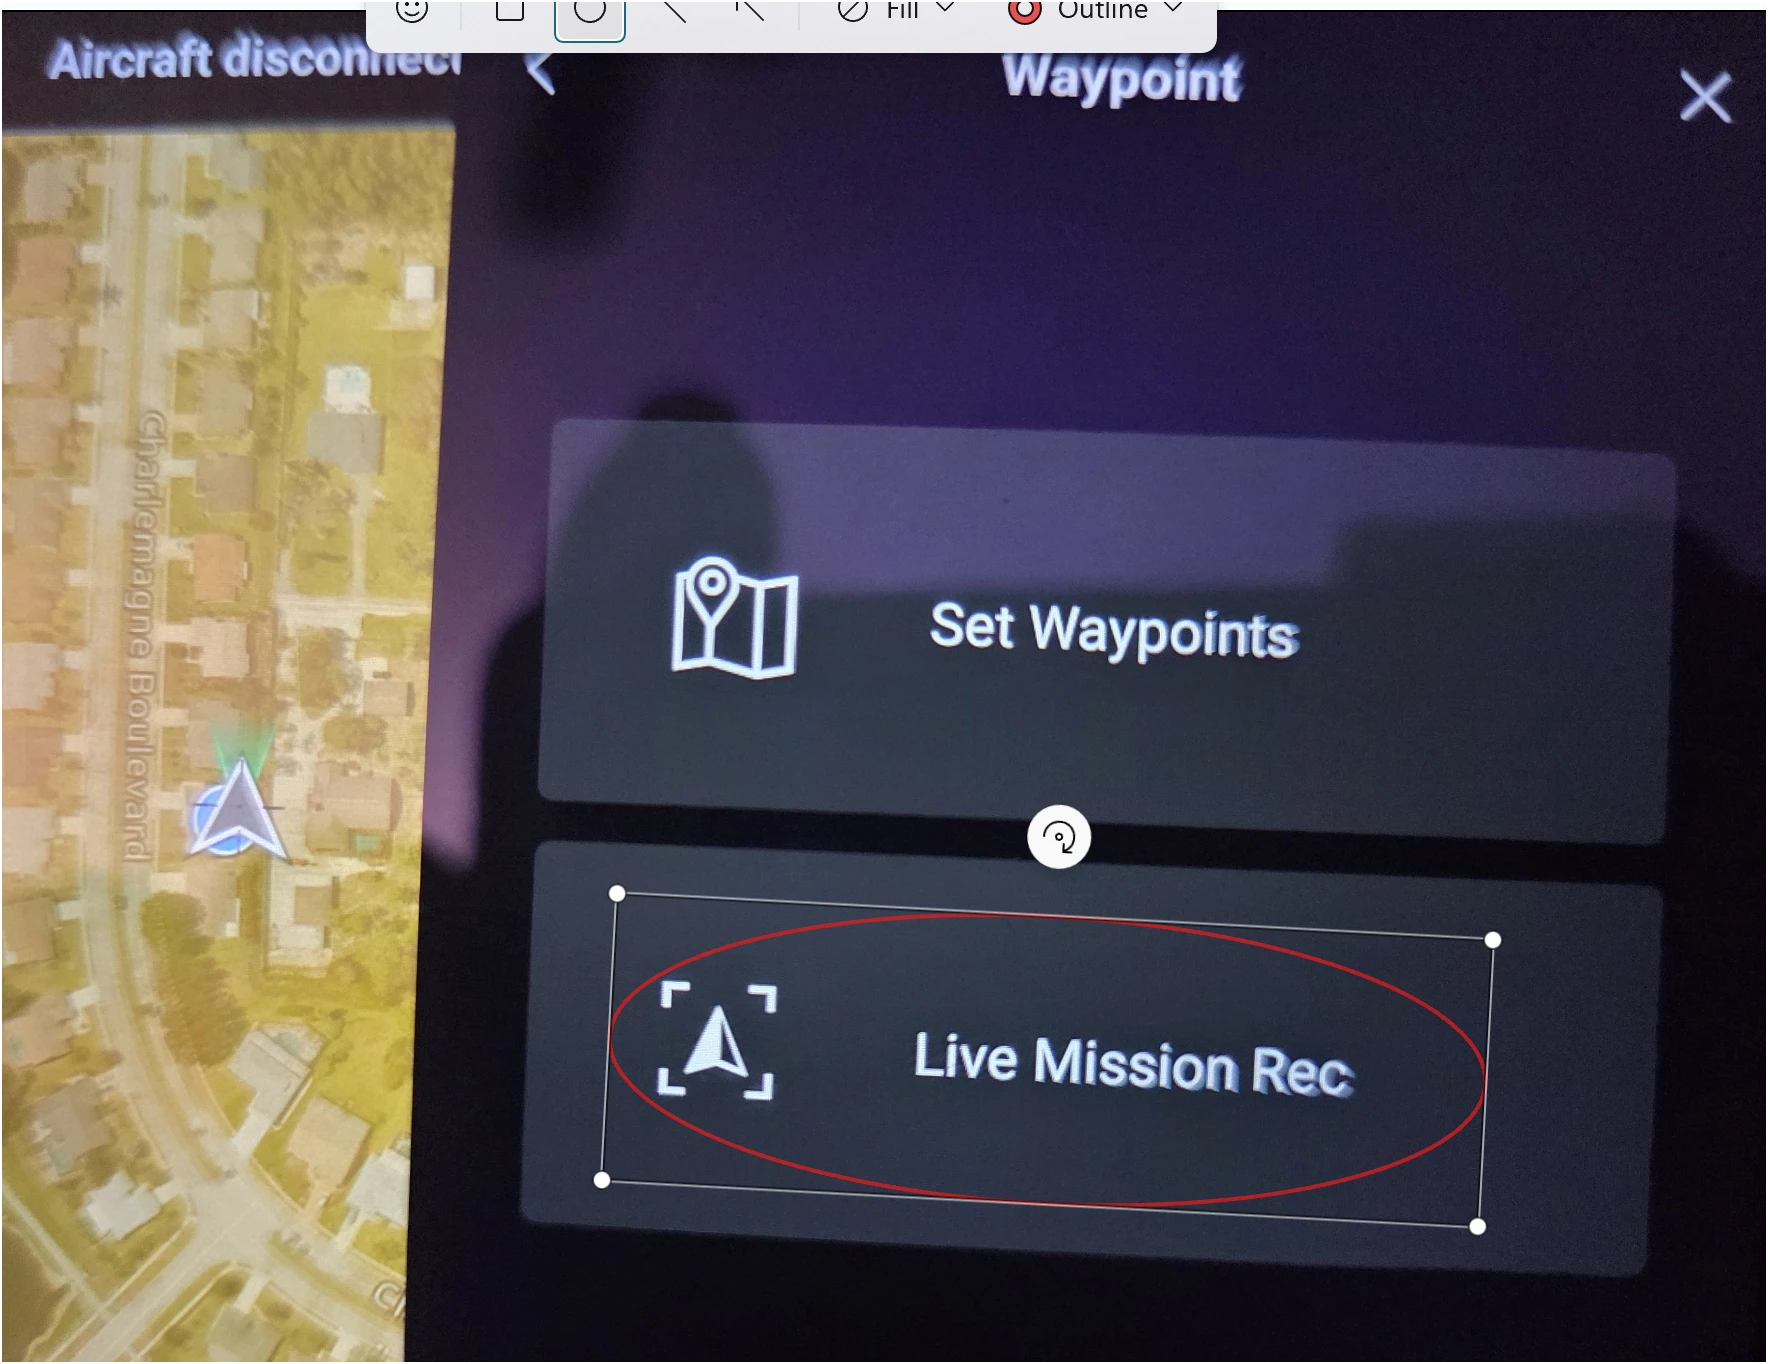
OK, agreed - the “Set Waypoints” (on the map) seems to work. Problem half fixed. So here is the issue. When Creating the Waypoint mission in Pilot 2, using the “Live Mission Rec” approach there is a failure. I built a 2 WP mission with 2 different WP’s with 2 different Gimbal settings, using the capture photo button on the controller. The KMZ file is attached as is the Waylines.wpml subfile. The Waylines.wpml file shows 2 WP’s with 2 different gimbal pitches. So the resulting Litchi mission should have 2 WP’s with 2 different gimbal pitches. However when I use the Litchi Bridge to bring them into Litchi Hub, the 2 WP’s show the pitches at 0 degrees. Is Litchi selecting the right .wpml folder/file in this case?
Waypoint4.kmz (3.5 KB)
waylines.wpml (9.0 KB)
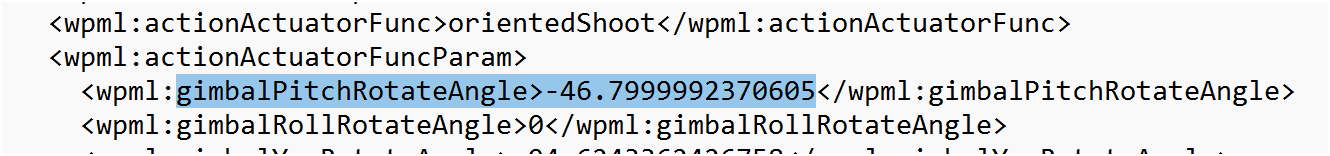
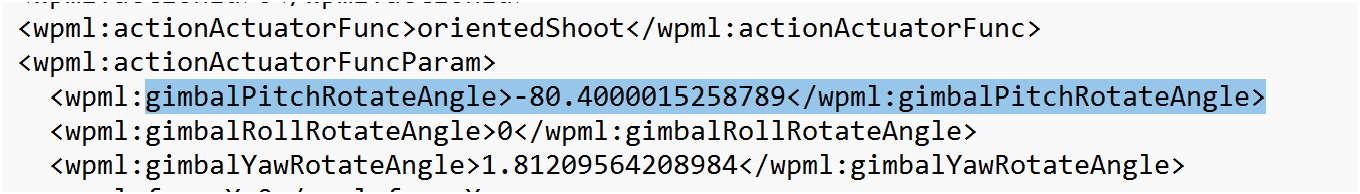
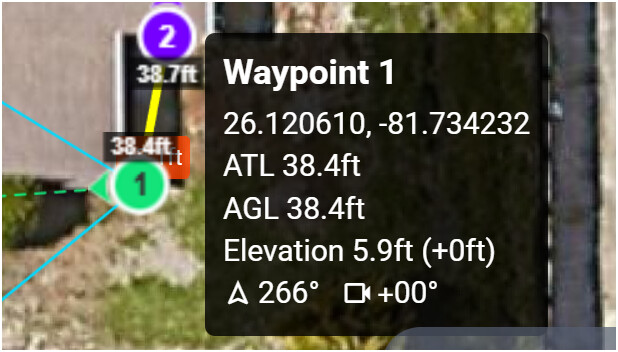
Your previous DJI KMZ file had the gimbal pitch mode set to “manual” in the template.kml portion of the KMZ file. The template.kml file is probably ignored in the conversion process so that didn’t really affect the conversion. The waylines.wpml file had gimbal pitches set to 0 (zero). That is why your original file didn’t result in any non-zero gimbal pitch angles in the conversion.
In this new submission, the gimbal pitch mode is still set to “manual” in the template.kml portion. Again, the template.kml file is probably ignored in the conversion process so that doesn’t matter.
While this KMZ file does contain non-zero gimbal pitch angles, they are part of a “orientShoot” camera/waypoint action and are triggered by the drone reaching a waypoint. I am guessing that Litchi’s conversion process is ignoring any “orientShoot” action because it does not have an equivalent in Litchi. I would ignore this action trigger in my conversion utility as well.
While I am not familiar with DJI Pilot 2, what you need to create is a gimbal pitch that transitions from one waypoint to the next. This would correspond to a “Custom” gimbal pitch mode in Litchi. The WPML code that would successfully be converted would include:
- ActionTrigger: betweenAdjacentPoints
- ActionActuatorFunc: gimbalRotate
- GimbalPitchRotateAngle: [non-zero value]
Alternatively, you could create a standard gimbal rotate camera action in DJI Pilot 2. That would be converted to the equivalent camera action in Litchi. In the WPML language, that would be represented by:
- ActionTriggerType: reachPoint
- ActionActuatorFunc: gimbalRotate
- GimbalPitchRotateAngle: [non-zero value]
I don’t know if this will help. Since I am not familiar with DJI Pilot 2, I cannot provide the details of how to do that with DJI’s software.
Thanks Wes. However I have no control over the gimbal pitch mode (set to “manual”) in Pilot 2 or the resulting KML file. The only control I have is flying the M3E, pointing the camera and clicking the Photo button. This action creates the waypoint. I save the waypoint mission (no capability of setting any parameters), and then import it with Litchi Bridge into Litch Hub. There are not options to set Gimbal mode anywhere in the workflow in either Pilot 2 or Litchi. Funny thing is, the DJI Fly app does a good job of bringing in the Waypoint Gimbal angles. Maybe the Litchi Bridge throwing in the defaults when selecting “Import from DJI Pilot”, or maybe DJI is storing the Gimbal pitches in a different place. Something is different.
Litchi does provide that option. It is called “Gimbal Pitch Mode”. With that set to “Custom”, you can specify the gimbal pitch at every waypoint.
Litchi Bridge is just a transfer utility. What I was trying to explain in my previous post is that DJI Pilot 2 is storing the gimbal pitches in kind of a weird/non-standard “orientShoot” action. There is no equivalent in Litchi. That is why they are probably being ignored.
Try to import it again, now Litchi Hub recognizes DJI Pilot 2’s special orientedShoot waypoint actions and converts it to an equivalent set of actions: rotate aircraft + tilt camera + zoom + take photo
Tried it again a few time… still same issue. Kept trying it then BAM! the import started to work and Gimbal angles appeared on the WP’s! Problem Fixed! Thanks Vico! You’re the best! Hey Wes - Thank you too. The Gimbal Pitch Mode is only setable after the import has completed unless I am missing something. I didn’t see any way to set it before the import step. Anyway it still defaults to Manual after the import is finished, but that doesn’t seem to be a problem now. The simulation and flight works out right.
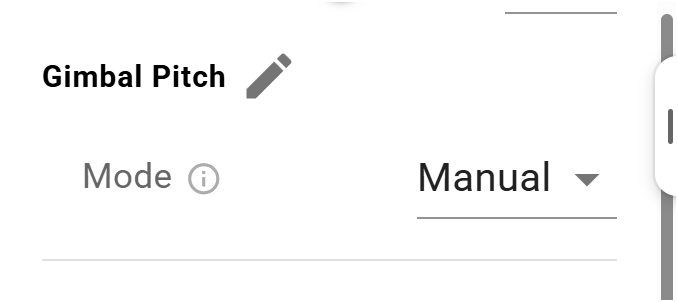
Your KMZ has gimbal mode set to Manual, so it imports correctly as Manual.
In DJI Pilot 2, you can set the gimbal mode to ‘Manual’ or ‘For Each Waypoint’, default is ‘Manual’.
If you plan using ‘Live Misison Rec’ then I guess DJI automatically sets it to Manual.
It does not matter anyway as all your flight does it take photos at specific heading/gimbal angles, it does not really use the mission’s gimbal mode in itself to achieve that, just waypoint actions.