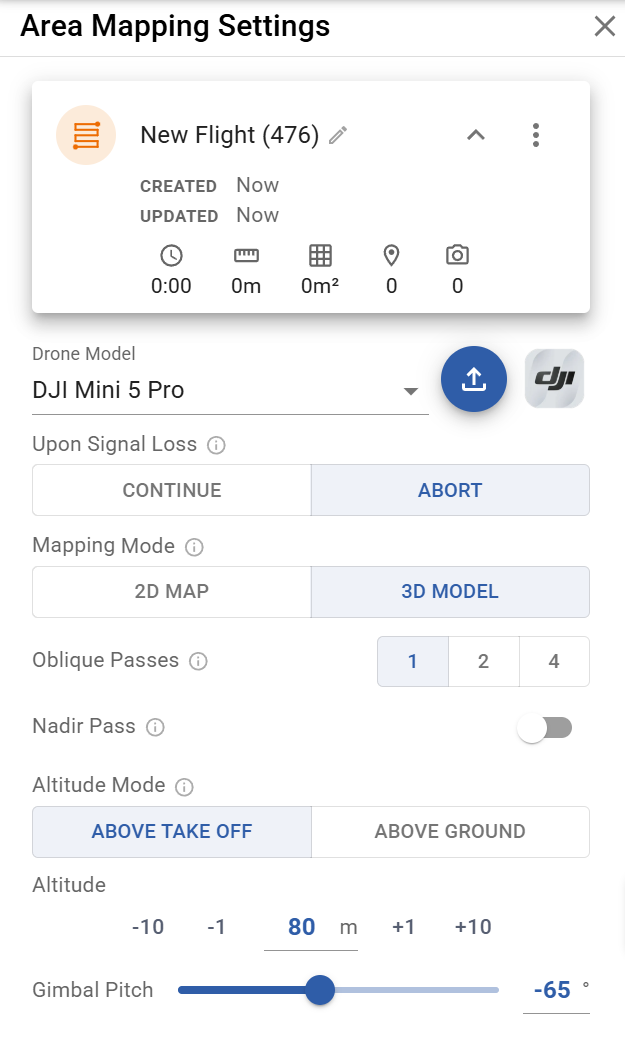
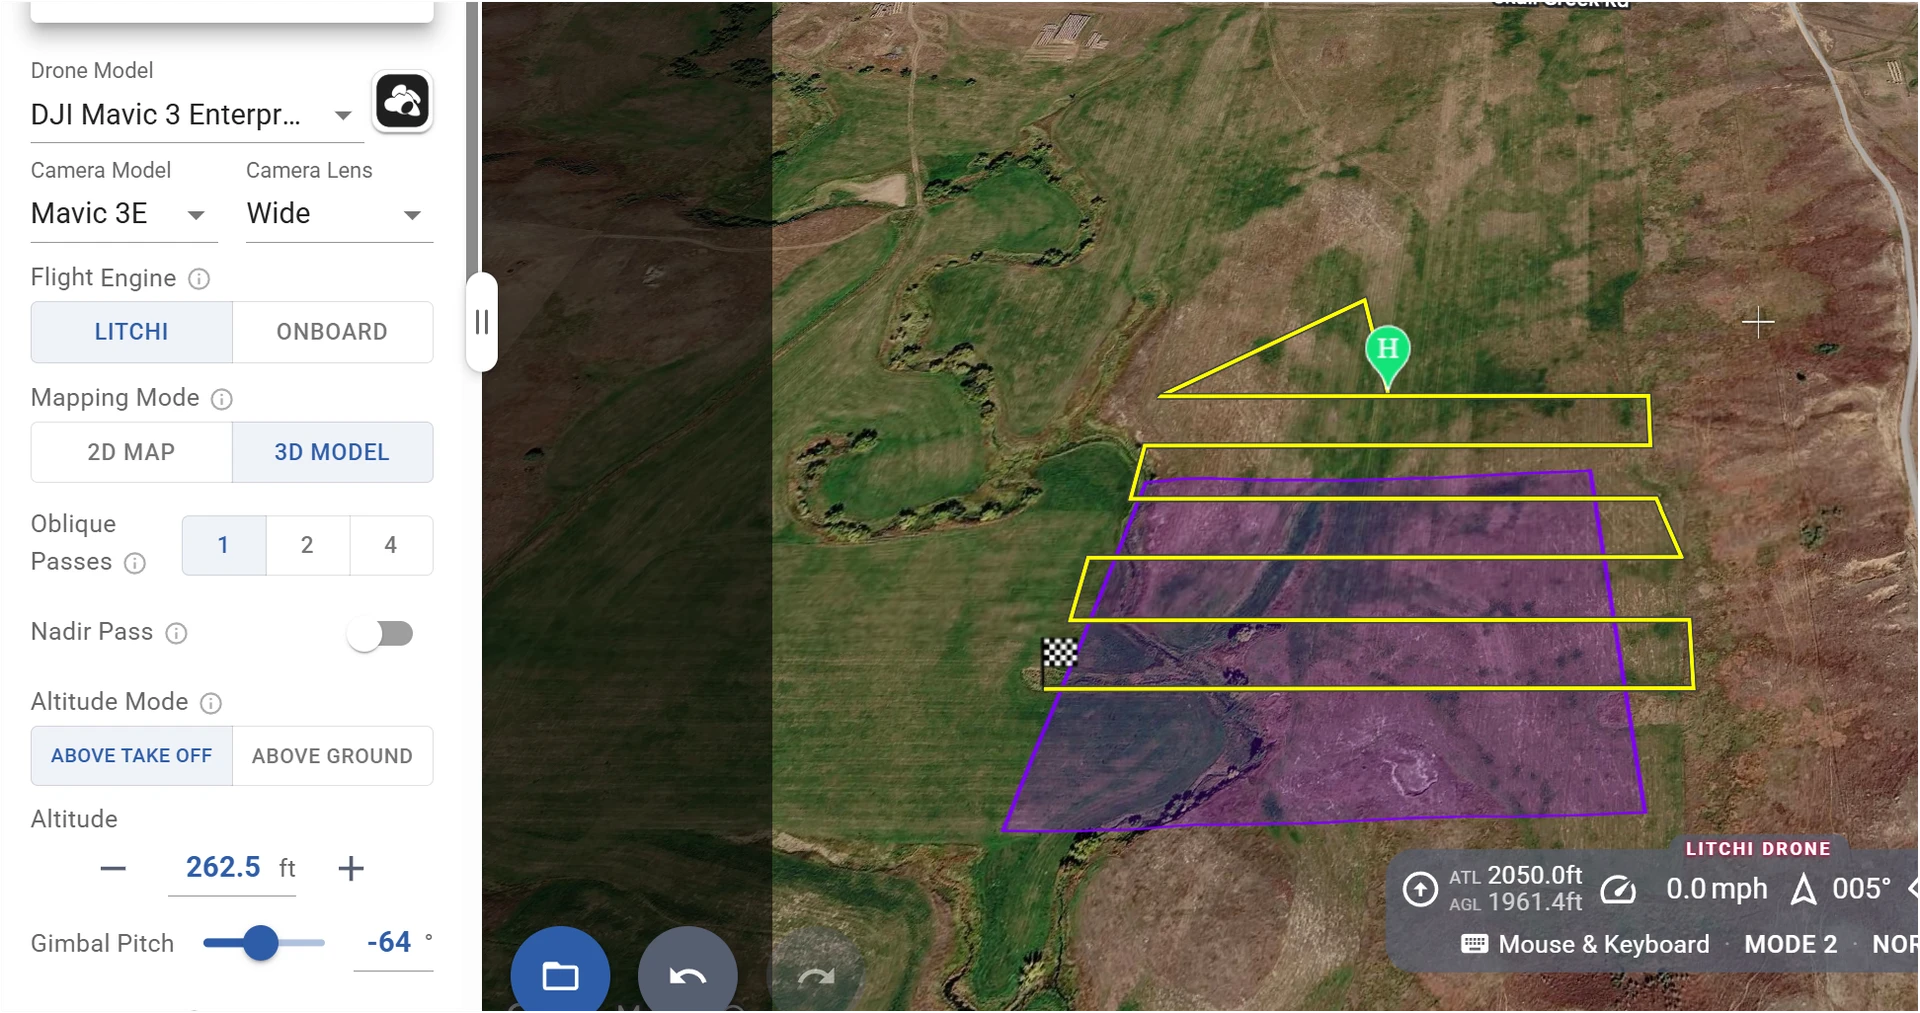
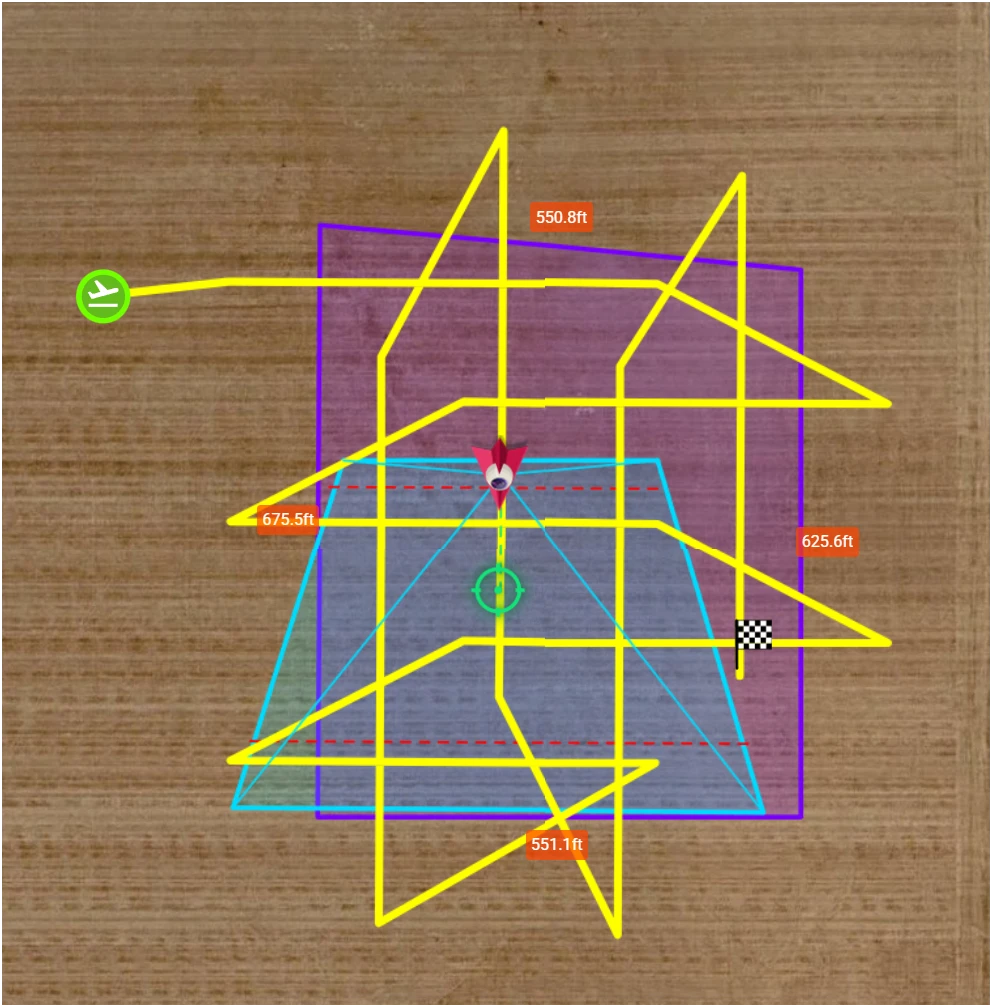
The option to set the gimbal tilt has disappeared! I searched to configure a 2D mapping mission and I can’t find it anymore.
(Has the gimbal pitch mode disappeared from area mapping?)
If they really removed it, this option was very important.
In my case, a cross-flight, one pass at nadir and another at 65º/70 degrees, was sufficient.
Estoy haciendo la planificación del vuelo el 2d, donde quiero tener un Angulo de cámara en 85 grados. Pero ya no aparece esa opción. Y la otra cuestión es que cuando pongo el simulador el ángulo de la cámara esta en 0 grados, es decir mirando al horizonte. Como se podría resolver esto? Gracias
Muchas gracias. Se ha resuelto el inconveniente que tenia… Ahora surge otra cuestión, al ingresar al mapeo 3D MODEL no aparece la opción de seguir camino, por tal motivo el drone en todo momento esta en una sola dirección; lo ideal es que en la primera linea vaya en una dirección y en la linea consecutiva vuelva de forma opuesta y así sucesivamente. Gracias
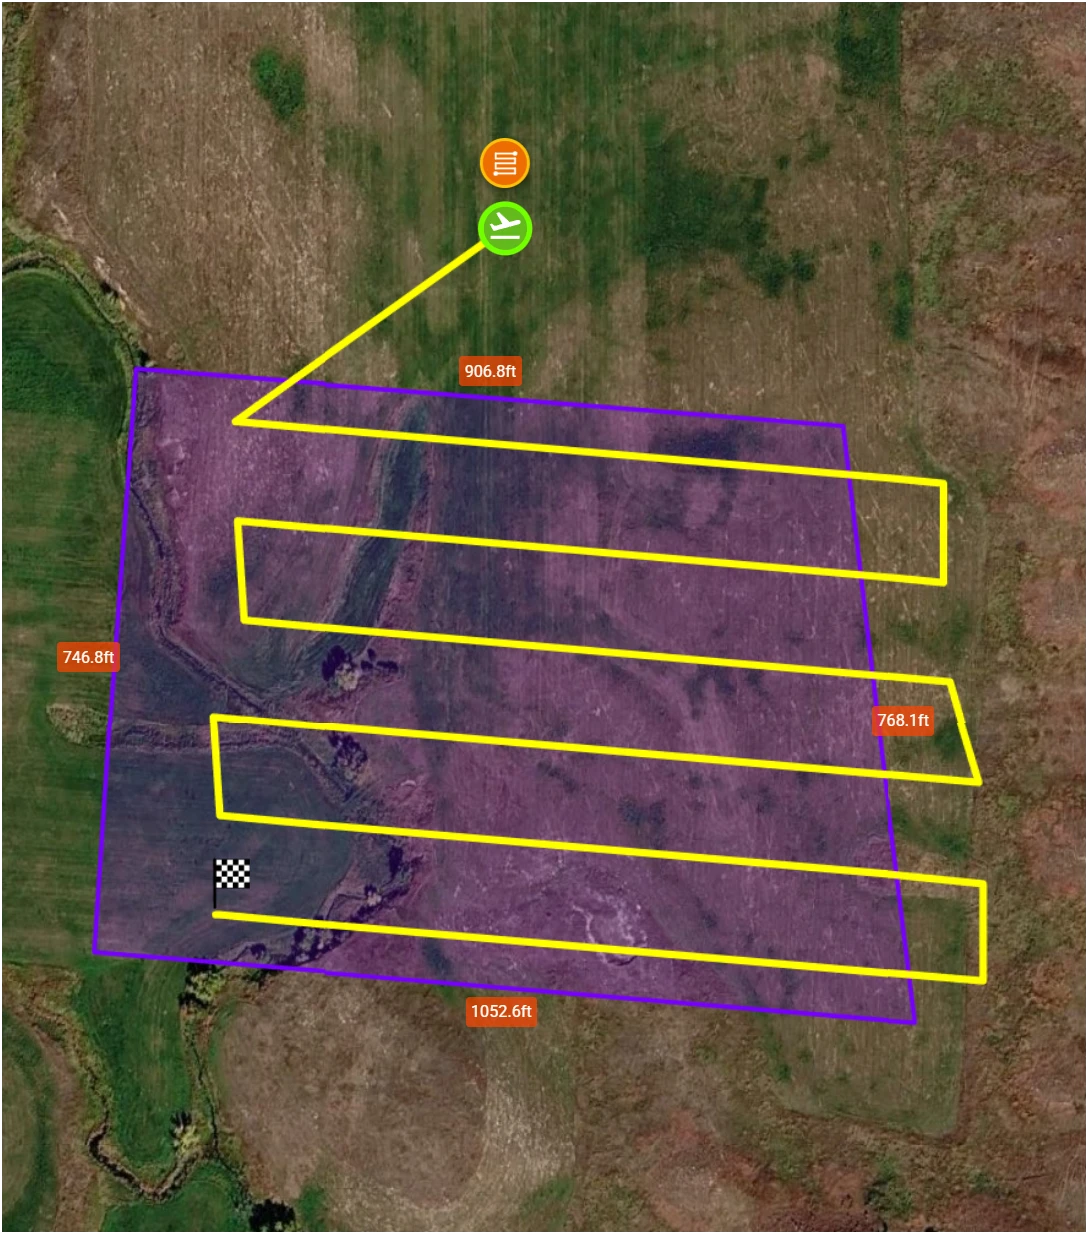
There may be a “One Sided” implementation of the obliques setting. Typically when flying a mapping mission with the gimbal set at less than 90 degrees, the lawnmower pattern requires both sides for the flightpath to extend over the mapped surface - not just 1 side. Here is the screenshot showing the lopsided lawnmower coverage. The right side has the 64 degree oblique perspective, but the left side does not. The Left Side flight path should extend equally to allow the 64 degree oblique perspective too. All fight planning apps have this standard - Drone Link, Drone Deploy, Maven, Flight Hub2, DJI Pilot 2, etc. Please can the flight path obliquest be made symmetrical over the mapping service?
This is intended, the drone’s heading/yaw is locked and will not change during the flight, such that only one side needs to be offset. Feel free to simulate the flight with the camera projection enabled and observe coverage is respected. Having it extend both sides would increase the total flight duration.
I agree - “ground surface” coverage is respected, but not equal oblique perspective from both sides/directions. The won’t make a 3D model if obliques occur from only one side. Also, in standard lawnmower coverage mode, shouldn’t the drone heading be pointed in the direction of travel soe the lawnmower covers both east and west walls of a building for example? This is not typical flight parameter for a supposed 3D capture. (like the other products mentioned).
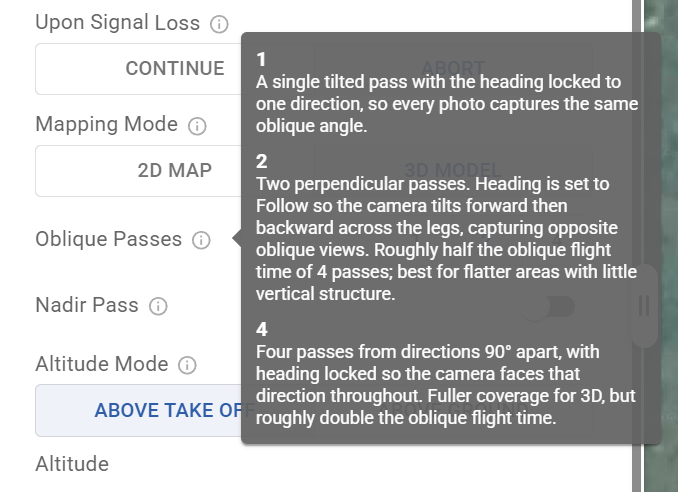
1 pass is never going to be enough for a 3D model regardless of how you offset it, the purpose of 1 pass is more if you want to plan and/or fly each pass separately.
The 2 pass mode does alternate the offset and would produce a 3D model although it won’t beat 4 passes, one full on each side.
The 2 pass mode will record 2 oblique angles, offset 90 degrees to the other. Great for North and West -or- South and East sides of a building. I seem to recall the 2D mode used to allow symmetric obliques overlaps and the drone heading would follow the flightpath. Maybe I recall this from Maven or Dronelink (but I thought it was Litchi), but this was perfect. Thanks.
Yes in Grid mode, Drone Heading = Follow Path. Not so in Lawnmower mode. Also it overlaps in only 1 side on the surface capture. Internally inconsistent behavior between 1 pass and 2 pass oblique mode.
So it also differs from prevalent standard in all other products. At best its a known error.
It is not inconsistent, it is intended.
2 pass is a quick method to get a 3d model, because the offset alternates, the coverage from each side is reduced so it won’t give you the best result. 2 pass only produces a reasonable 3d model because of Follow heading mode, and that’s why it uses that.
4 pass is the full method to get the 3d model, and uses Locked heading mode.
1 pass we added because of user request, it does not produce a reasonable 3d model on its own
What you’re asking is for the Heading Mode setting to be adjustable when in “1 pass” mode, which we will consider adding, however it would help if you tell us the use case for that.
I appreciate the openness to the request. Litchi is already a fantastic product with a very bright future, The use case is many DSPs (Zeitview, FlyGuys, etc.) ask for Lawnmower pattern mapping of a property and building roof with gimbal set at 75 degrees. The drone points in the path direction always. Overlap at both ends of the lawnmower pattern facilitate 3d coverage in the forward and return direction natively. (With shorter of the 4:3 aspect) of the frame. Flying with heading along the path with extensions overlapping at both ends of the flightpath ensures wall and 3d coverage in both forward and return directions.
No Need to do crosshatch grid - because the horizontal direction (longer of the 4:3 frame aspect) of the frame has sufficient oblique angle on the sides of the frame to cover the sideways reconstruction of the property and building. I hope that made sense. Using the 2 Pass oblique setting doubles the flight time and battery consumption unnecessarily. It may also double the actual % overlap needed in actuality (but I have not tested this yet).
So, having a selection to set Heading Mode = Along Path would mimic this use case mission requirement.
By the way, the 2 pass oblique setting does perform the Heading Mode = Along Path - and each direction makes the drone heading point along the path, including the flight extensions at each end of the flight segment. Its perfect:
The the 4 pass oblique mode however reverts to Heading Mode = Fixed Direction for all 4 directions separately and sequentially. Not as efficient.
Lastly please consider the 2 pass mode optimal from a safety point of view. It is far better to have the drone always facing forward along the flight path, both from the pilot visibility seeing possible obstructions on the flight path ahead, and also having forward facing collision avoidance sensors pointing forwards. It’s the best using the 2 oblique setting configuration - Drone always safely facing forwards.
It is a lot more risky in the 1 pass and 4 pass oblique modes since the drone is flying backwards half the time and the pilot and sensors don’t have visibility to obstructions (on many drone). This should be an important safety consideration.